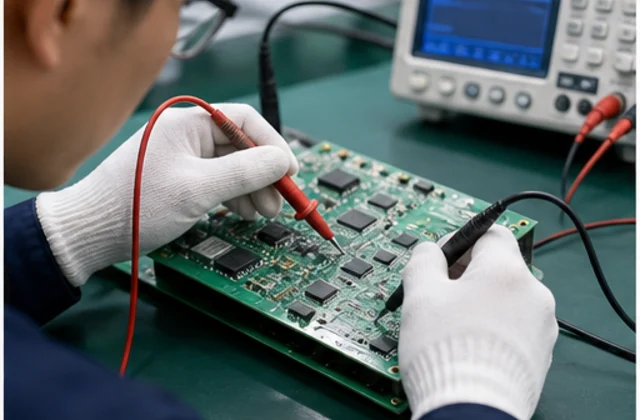
 Functional Inspection
100% tested on professional platforms to ensure stable performance.
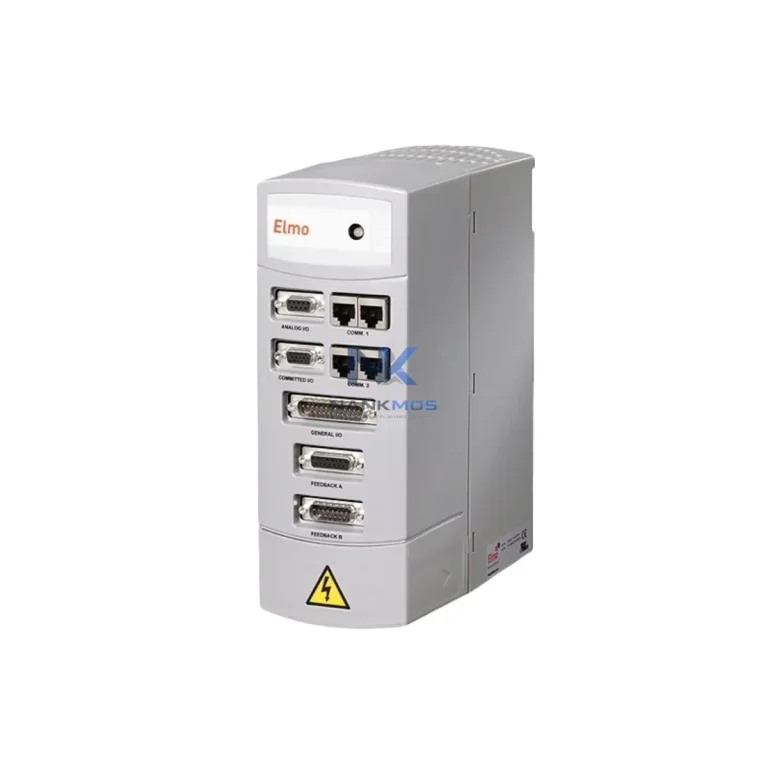
Elmo Motion Control G-DRU20/400EEH0 G-DRU20/400EEHO is a NANKMOS industrial automation product record Listed under Other series series and Drives. Confirm condition, availability, lead time, compatibility and documentation by email inquiry.
Brand names are used for identification only.
Elmo Motion Control G-DRU20/400EEH0 G-DRU20/400EEHO is a NANKMOS industrial automation product record Listed under Other series series and Drives. Confirm condition, availability, lead time, compatibility and documentation by email inquiry.
| Manufacturer | Elmo Motion Control |
|---|---|
| Application | Motion Control & Drive System |
| Part Number / Model | G-DRU20/400EEH0 G-DRU20/400EEHO |
| Compatible System | Confirmed by inquiry |
| Condition Options | To Confirm |
| Module Type | Servo / Drive Module |
| Warranty | 12 Months |
| Packaging | Anti-static Bag / Secure Box |
| Shipping Methods | DHL / FedEx / UPS / Air / Sea |
| Availability | To Confirm |
| Lead Time | To Confirm |
| Documentation | Part number and revision checked before quote |
The Elmo G-DRU20-400EEH0 is a high-performance EtherCAT servo drive module engineered for the Gold Series motion control platform. Designed to operate at the intersection of real-time motion execution and industrial network communication, this drive delivers deterministic control cycles, seamless protocol integration, and robust data transparency across the full automation data chain — from field-level actuators to SCADA supervisory systems.
In modern smart factory environments, servo drives are no longer isolated motion components. They are active nodes in a connected data architecture. The G-DRU20-400EEH0 leverages EtherCAT's distributed clock synchronization to achieve sub-microsecond cycle alignment with upstream controllers, enabling precise multi-axis coordination across complex motion profiles. Whether integrated into a Beckhoff TwinCAT motion controller, a Siemens S7-1500 with EtherCAT master capability, or a dedicated Elmo Gold Maestro multi-axis controller, this drive maintains real-time feedback loops that are essential for high-speed positioning, tension control, and synchronized gantry applications.
Signal acquisition begins at the encoder interface. The G-DRU20-400EEH0 supports high-resolution feedback devices including incremental encoders, absolute encoders (EnDat, BiSS-C, Hiperface), and resolver inputs, feeding position and velocity data directly into the EtherCAT process data object (PDO) cycle. This data is transmitted upstream to the motion controller and simultaneously made available to HMI panels and SCADA platforms via OPC-UA gateways or Modbus TCP bridges — enabling real-time visualization of torque curves, position error, and drive health status without interrupting the control loop.
For facilities running mixed-protocol environments, the G-DRU20-400EEH0 integrates cleanly alongside protocol conversion gateways such as the HMS Anybus X-gateway or Moxa MGate series, which translate EtherCAT process data into PROFINET, EtherNet/IP, or Modbus TCP for upstream SCADA or MES connectivity. This eliminates data silos between motion-layer devices and plant-level monitoring systems, giving operations teams full visibility into drive performance, fault history, and energy consumption from a centralized dashboard.
Remote diagnostics are a core operational advantage of the G-DRU20-400EEH0 architecture. Through the EtherCAT mailbox protocol and CoE (CANopen over EtherCAT) object dictionary, maintenance engineers can remotely read drive parameters, fault registers, and thermal status without physical access to the control cabinet. When paired with an edge gateway such as the Advantech WISE-5000 series or a Hilscher netIOT Edge device, drive telemetry can be pushed to cloud-based analytics platforms for predictive maintenance scheduling and OEE tracking.
The drive's compact form factor and DIN-rail mounting compatibility make it suitable for high-density servo panels in packaging lines, semiconductor handling equipment, medical device assembly, and precision CNC applications. Its 400V AC input rating and 20A continuous output current support a wide range of servo motor frame sizes within the Elmo Gold motor family, as well as compatible third-party servo motors meeting IEC 60034 standards.
System expansion is straightforward. The G-DRU20-400EEH0 supports daisy-chain EtherCAT topology, allowing additional drives — including the Elmo G-DRU10-200EEH0 for lighter axes or the G-DRU40-800EEH0 for high-torque applications — to be added to the network without reconfiguring the master controller. The Elmo Application Studio (EAS) software provides a unified commissioning and diagnostics environment, supporting auto-tuning, scope capture, and network topology visualization across all connected Gold Series drives.
Every G-DRU20-400EEH0 unit shipped by NANKMOS undergoes pre-shipment functional testing covering EtherCAT communication handshake, encoder feedback verification, current loop response, and fault injection testing. Units are supplied with a 12-month warranty covering manufacturing defects and communication interface failures. Stock is maintained for immediate dispatch, with global logistics support for urgent automation project timelines.
In a fully connected smart factory deployment, the G-DRU20-400EEH0 operates as a real-time data node within a layered automation architecture. At the field level, servo motors equipped with EnDat 2.2 absolute encoders feed position and velocity data into the drive's feedback processor at update rates exceeding 10 kHz. This data is encapsulated into EtherCAT PDOs and transmitted upstream to the motion master — typically an Elmo Gold Maestro multi-axis controller or a Beckhoff CX2040 embedded PC running TwinCAT 3 — within a single network cycle.
The motion master aggregates position data from multiple G-DRU20-400EEH0 drives across a daisy-chain segment, coordinating synchronized multi-axis profiles for applications such as flying shear cutting, pick-and-place robotics, or web tension control. Simultaneously, the EtherCAT master exposes drive status objects — including following error, motor temperature, DC bus voltage, and fault codes — to an OPC-UA server running on an industrial PC or edge gateway such as the Advantech UNO-2484G.
From the OPC-UA layer, data flows to SCADA platforms including Wonderware System Platform, Ignition by Inductive Automation, or Siemens WinCC, where operators monitor drive health, production throughput, and alarm states in real time. HMI panels — such as the Weintek cMT series or Siemens TP1200 Comfort — display axis position, speed, and torque trends directly from the OPC-UA data source, providing machine operators with actionable feedback at the cell level.
For facilities requiring integration with ERP or MES systems, a Hilscher netIOT Edge gateway bridges the EtherCAT motion network to MQTT or REST API endpoints, enabling drive cycle counts, energy consumption data, and fault event logs to be pushed to cloud analytics platforms or SAP manufacturing modules. Remote I/O modules such as the Beckhoff EL1008 digital input terminal or Phoenix Contact Axioline F series can be added to the same EtherCAT segment, expanding the network to include proximity sensors, safety relays, and pneumatic valve control without additional fieldbus infrastructure.
Variable frequency drives (VFDs) controlling auxiliary motors — such as the ABB ACS880 or Yaskawa GA800 — can be integrated into the same supervisory layer via Modbus TCP or PROFINET, with their status data aggregated alongside G-DRU20-400EEH0 servo data in the SCADA historian. This unified data architecture eliminates the traditional boundary between motion control networks and process control networks, enabling plant-wide OEE analysis and predictive maintenance across all rotating equipment.
Many automation sites operate with servo drives that are mechanically functional but informationally isolated — generating no usable data for maintenance teams, production planners, or quality engineers. The G-DRU20-400EEH0 addresses this directly through its native EtherCAT connectivity and rich CoE object dictionary, which exposes over 200 drive parameters to the network without requiring custom programming or proprietary software licenses.
Protocol fragmentation is a common barrier to plant-wide data integration. Sites running a mix of PROFIBUS, DeviceNet, and EtherCAT devices often rely on manual data collection or isolated SCADA islands. By deploying the G-DRU20-400EEH0 alongside an HMS Anybus Communicator gateway, EtherCAT process data can be translated to PROFINET or EtherNet/IP in real time, feeding existing SCADA historians without replacing legacy infrastructure.
Remote monitoring eliminates the need for on-site diagnostics visits for routine fault analysis. Through the EtherCAT mailbox and CoE emergency objects, fault codes, over-temperature events, and encoder errors are logged with timestamps and transmitted to the SCADA alarm management system automatically. Maintenance engineers can acknowledge alarms, read fault history, and initiate drive resets remotely — reducing mean time to repair (MTTR) and minimizing unplanned downtime.
Production line transparency is achieved by mapping G-DRU20-400EEH0 cycle data — including completed motion profiles, position accuracy statistics, and energy per cycle — to MES production records. This enables quality teams to correlate servo performance data with product quality metrics, identifying drift in positioning accuracy before it results in out-of-tolerance parts. System expansion is non-disruptive: additional drives are added to the EtherCAT daisy chain and auto-detected by the master controller, with no changes required to the SCADA configuration.
Q: What is the minimum EtherCAT cycle time supported by the G-DRU20-400EEH0?A: The drive supports EtherCAT cycle times from 62.5 µs upward, with distributed clock synchronization ensuring all drives on the segment maintain sub-microsecond alignment. For most multi-axis motion applications, a 250 µs or 500 µs cycle time provides the optimal balance between network load and control bandwidth.
Q: Can the G-DRU20-400EEH0 be integrated into a SCADA system without an EtherCAT master?A: Direct SCADA integration requires an EtherCAT master controller (such as a Beckhoff IPC or Elmo Gold Maestro) as the network master. However, the master can expose drive data via OPC-UA or Modbus TCP to any SCADA platform, including Ignition, WinCC, and FactoryTalk, without proprietary middleware.
Q: How does the drive handle network interruptions or EtherCAT link loss?A: The G-DRU20-400EEH0 implements configurable watchdog timers that trigger a safe torque-off (STO) or controlled deceleration response upon EtherCAT link loss, depending on the application safety configuration. Network recovery is automatic upon link restoration, with the drive returning to operational state within one bus cycle after master re-synchronization.
Q: What warranty and pre-shipment testing does NANKMOS provide for this drive?A: Every G-DRU20-400EEH0 supplied by NANKMOS carries a 12-month warranty covering manufacturing defects, communication interface failures, and feedback interface faults. Pre-shipment testing includes EtherCAT communication handshake verification, encoder signal integrity check, current loop step response, and fault injection testing across all protection channels. Test records are available upon request.
Functional Inspection100% tested on professional platforms to ensure stable performance.
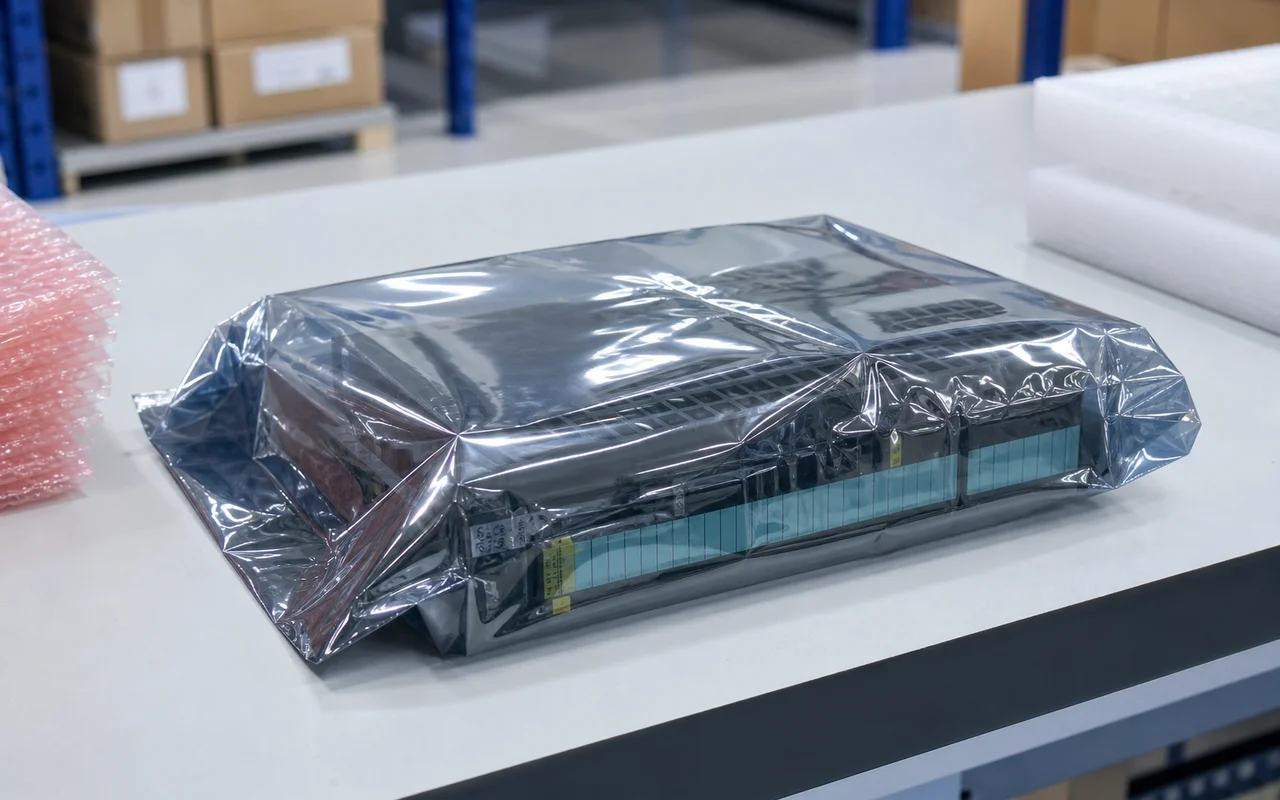 Anti-static Packaging
Modules are packed in anti-static bags to prevent electrostatic damage.
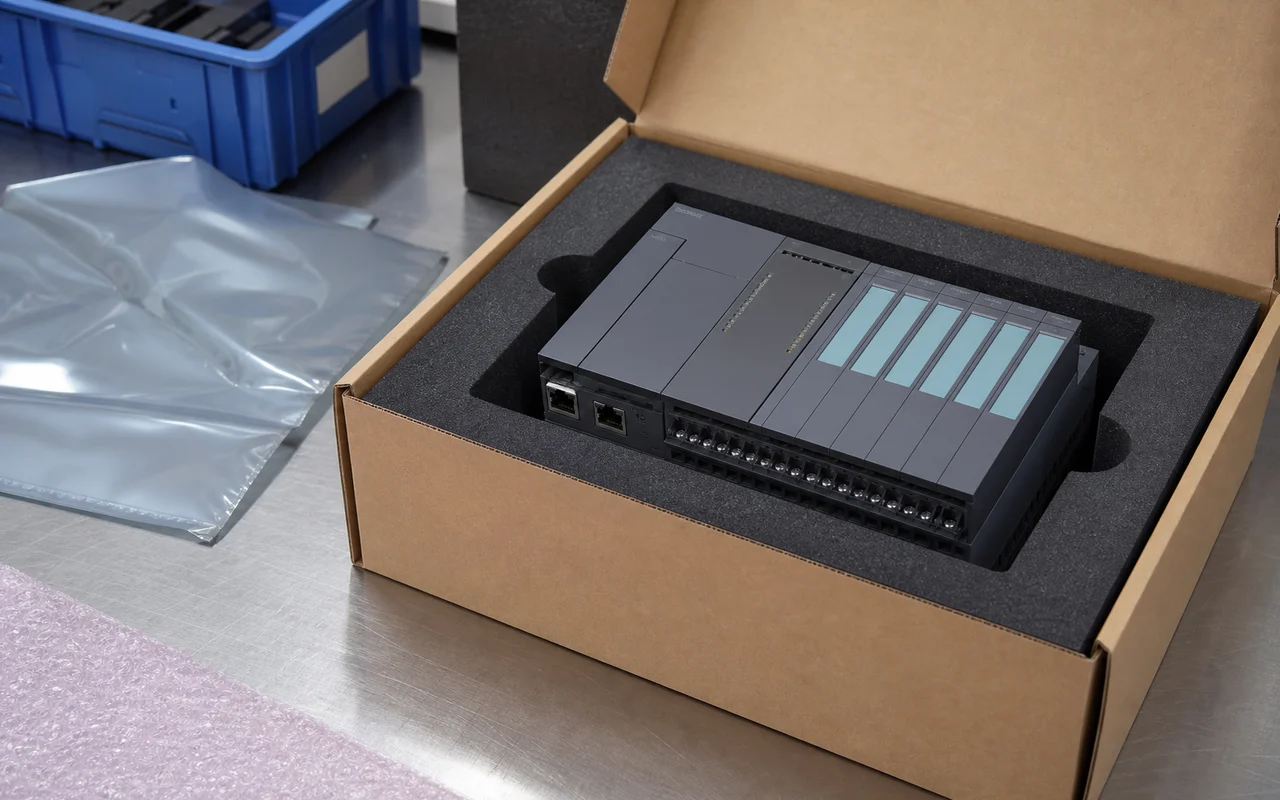 Secure Export Packing
Cushion protection and strong cartons ensure safe transportation.
 Worldwide Shipping
Global logistics network supports air, sea and express delivery.
 Documentation Check
Part number, revision and compatibility verified before shipment.
 After-sales Support
Professional technical support to help resolve your issues.